CRG vacuum grippers are manufactured from durable silicone and nitrile rubber for reliable sealing and high tear resistance. They are widely used to handle glass, sheet materials, paper, and other thin or lightweight workpieces in industries such as construction, printing, packaging, and glass processing.
Vacuum grippers provide clean, pneumatic handling without generating light, heat, or electromagnetic interference. They are easy to use, environmentally friendly, and designed to pick up and release workpieces without surface damage.
We respect your privacy. Your personal information is secure and will never be shared with third parties.
Vacuum Handling Guide
Choose a Vacuum Cup or a Complete Vacuum Gripper
A vacuum cup is the contact element that seals against the workpiece. A complete vacuum gripper combines one or more cups with mounting, vacuum generation, valves, tubing and sensing. Start with the workpiece and motion requirements, then select the complete system.
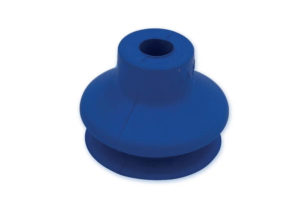
Vacuum Cups and Pads
Use individual cups or pads when you already have the frame, vacuum source and controls. Cup material, diameter, lip shape and mounting should match the surface, temperature and contamination conditions.
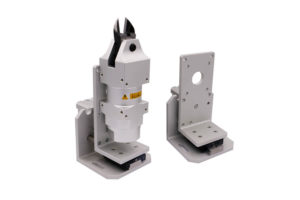
Complete EOAT Vacuum Gripper
Choose a complete gripper when the robot needs an integrated handling solution with cup layout, suspension, vacuum generation, valves, sensing and connection to the EOAT frame.
Four Selection Factors
Match the Gripper to the Workpiece
Surface
Flat, curved, textured, porous, oily or uneven surfaces require different cup profiles and sealing behavior.
Load and Motion
Consider workpiece weight, orientation, acceleration, emergency stops and the distance from the robot flange.
Vacuum Supply
Confirm available pressure or vacuum source, flow demand, evacuation time, tubing length and expected leakage.
Safety
Use an appropriate safety factor and consider check valves, vacuum monitoring and retained holding during supply loss.
Before You Request a Quote
Vacuum Gripper Selection Checklist
These details allow CRG engineers to evaluate cup type, quantity, layout and supporting components.
The answer depends on total required holding force, cup diameter, available vacuum, motion, workpiece rigidity and safety factor. Multiple cups can also improve stability and distribute force across thin sheets.
Which cup material should I choose?
Material selection depends on temperature, oil exposure, wear, marking restrictions and the workpiece surface. Send CRG the application conditions so compatibility can be checked.
Can vacuum grippers handle porous or uneven parts?
They can, but leakage and sealing must be evaluated. A suitable cup profile, higher flow vacuum source, foam sealing or a different gripping method may be required.
Can CRG design a complete vacuum EOAT?
Yes. Provide the workpiece drawing, weight, surface information, robot model, cycle data and available utilities. CRG can evaluate the cup layout and supporting EOAT components.
Get a vacuum gripper recommendation
Send the workpiece drawing, weight, surface, pick orientation, cycle time and robot model.